James Bruton Builds Autonomous Ball Wheeled Omni Directional Car That Travels in Any Direction
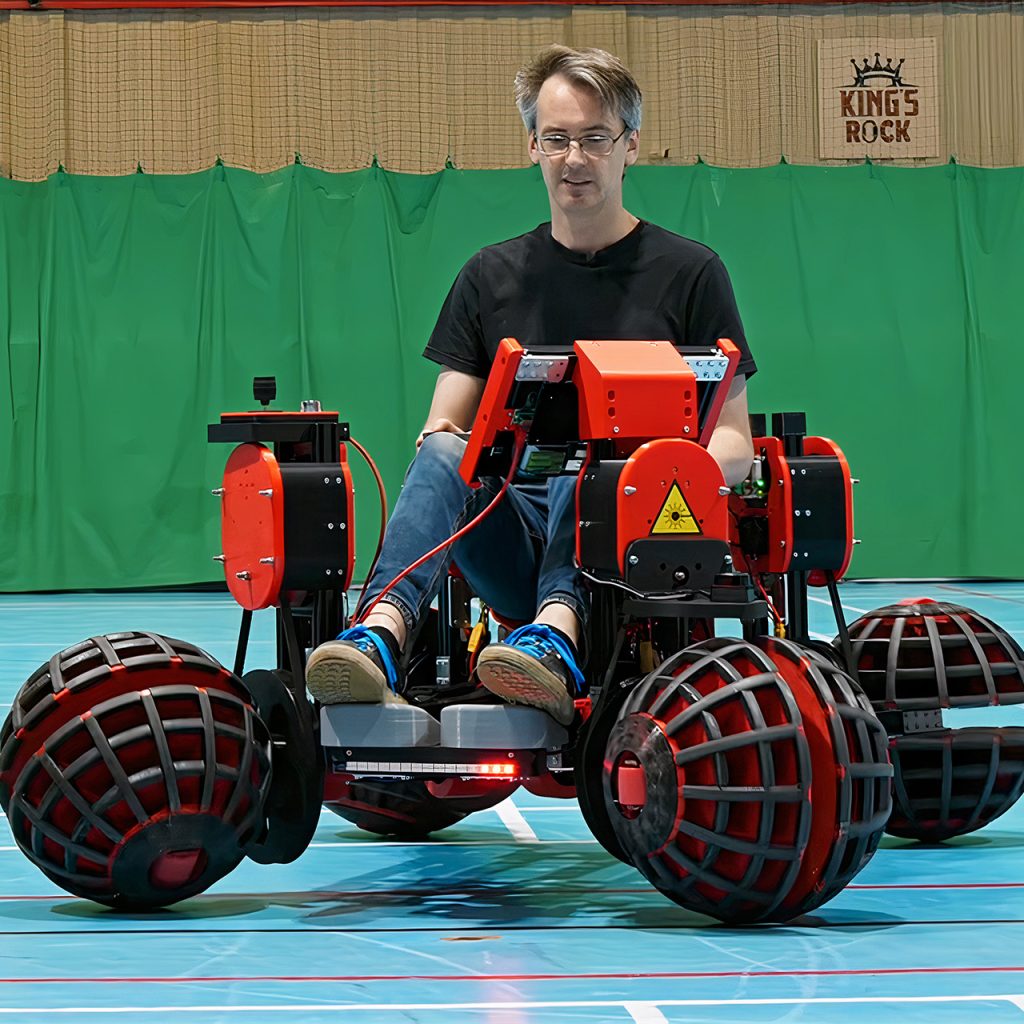
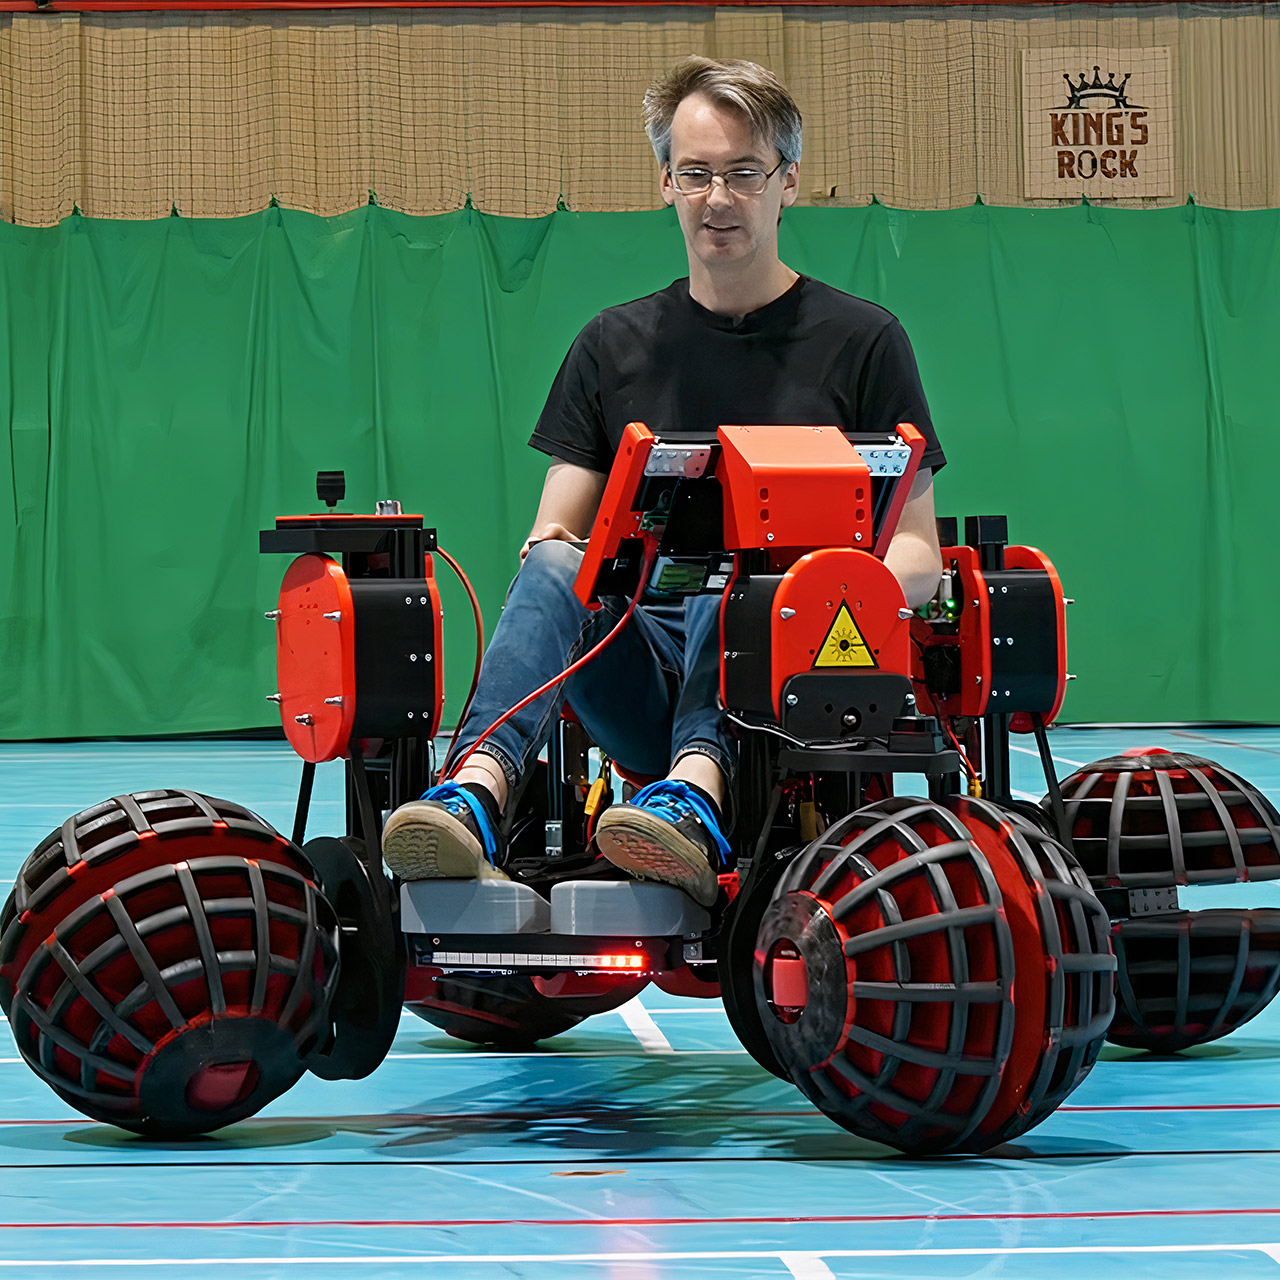
James Bruton has returned with a rideable electric vehicle that rests on four large ball wheels and handles its own navigation, sliding forward, backward, sideways, or spinning in place without ever turning its body toward a new heading.
Each ball wheel is made up of two hemispheres bolted to a shared T-shaped axle so that motors can push both of them in perfect sync down one axis while they still roll all over the place along the other, a setup that is a copy of some previous research done at Osaka University and is mounted at a forty-five degree angle all around the chassis as it sits there.
Sale

Hiboy S2 Electric Scooter – 8.5″ Solid Tires – Up to 17 Miles Long-Range | 19 MPH Portable Folding…
- POWERFUL MOTOR AND LONG BATTERY LIFE – The 350W electric brushless hub motor allows for speeds up to 18mph. High capacity battery with a Max. travel…
- STABLE AND DURABLE FOR COMMUTING – Extremely smooth when accelerating and turning, Hiboy electric scooters have been made solid and durable quality…
- BEING SAFER WITH TECHNOLOGY – Hiboy E-Scooter S2 are made with front, middle and rear 3 lights. And double braking system features a disc braking and…
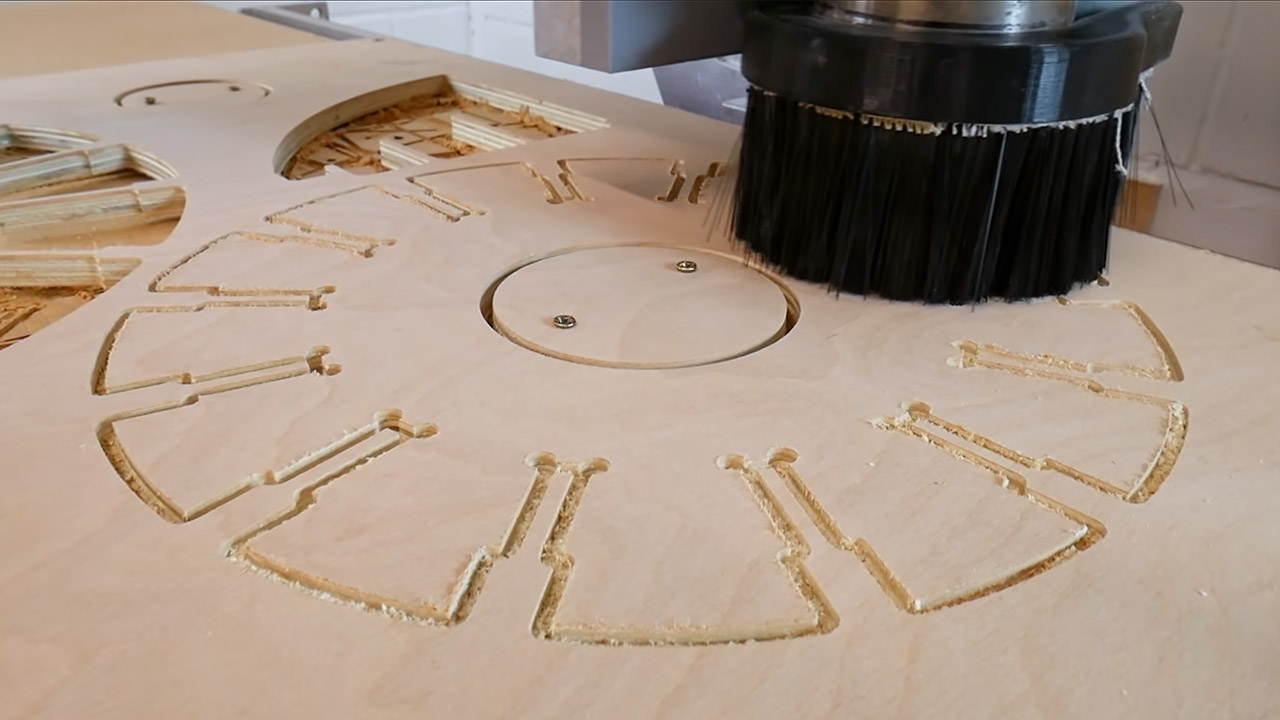
Bruton then used a CNC machine to shape those hemispheres by cutting 14 vertical ribs into a piece of plywood, as well as a batch of interlocking horizontal layers that snap together to form one solid shell, before wrapping the outside edges in good ol’ rubber for better grip and topping it all off with a 3D-printed dome.
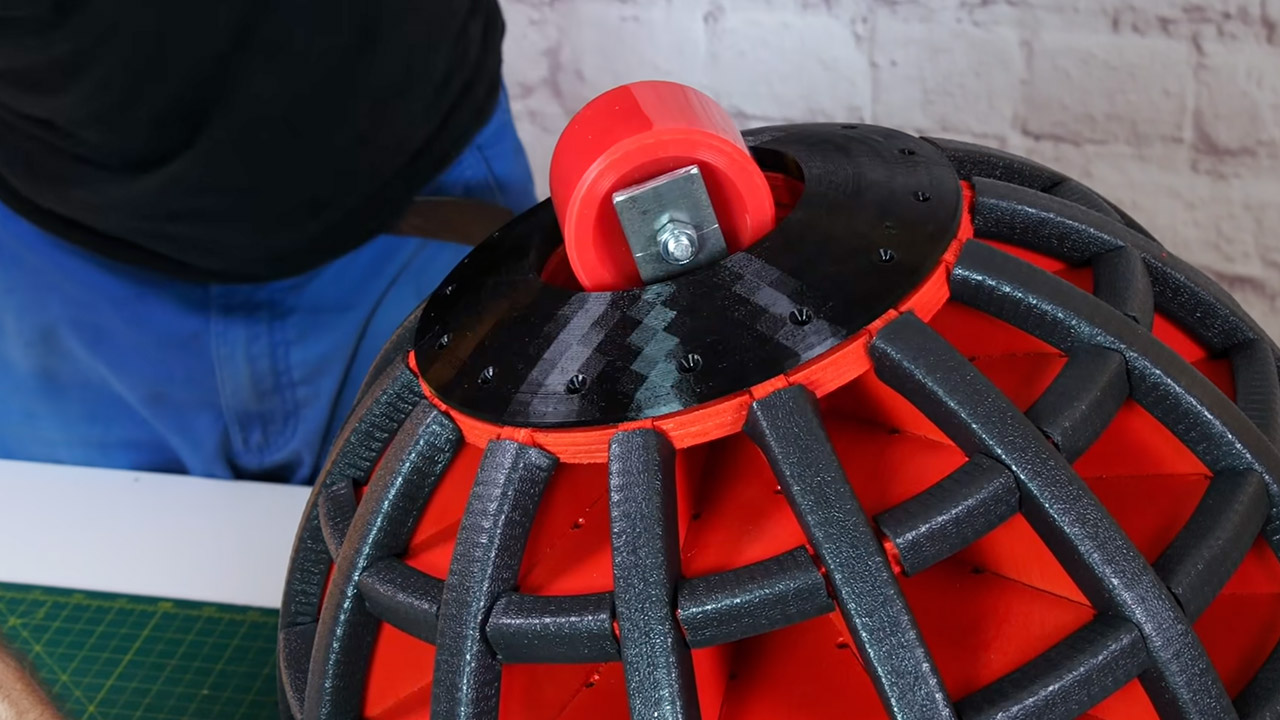
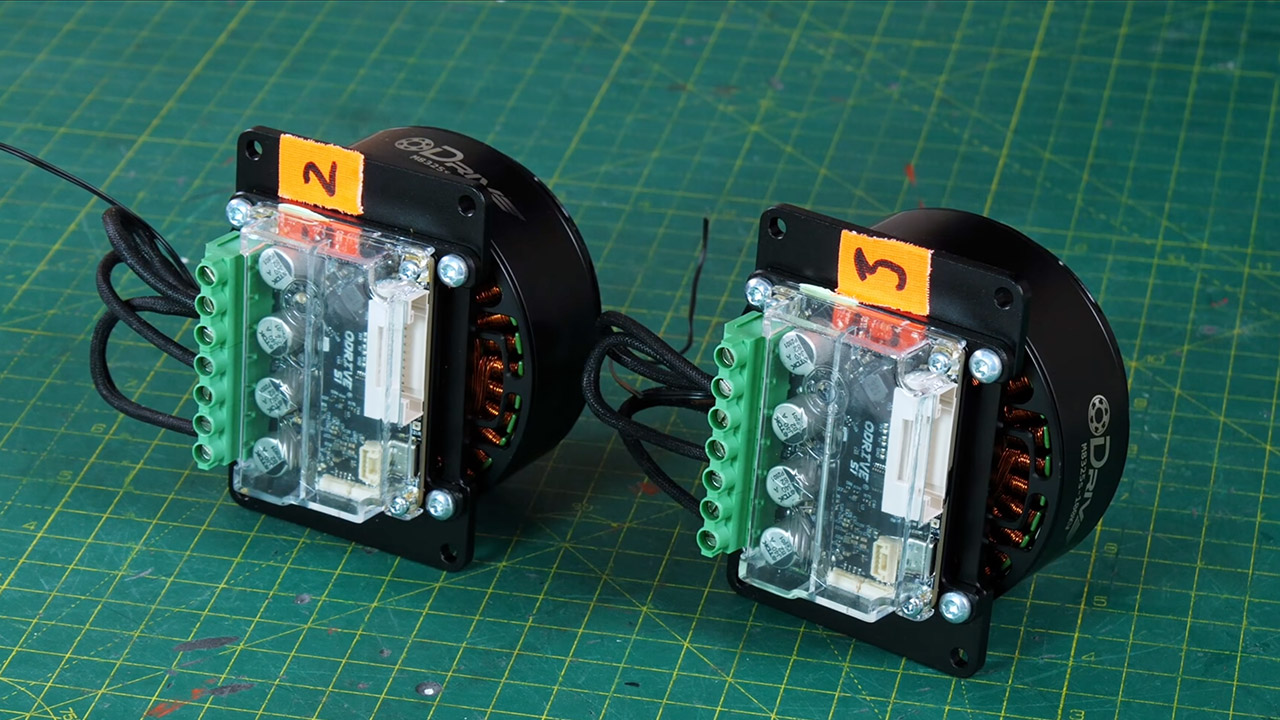
When you get up close to the inside of the poles, you’ll notice several little skateboard wheels hiding in there, which are responsible for allowing those ends to spin smoothly while the vehicle’s weight is parked on them. The primary frame and the axles that hold the heavy load bearings are built of aluminum extrusions. Four motors, each with a punch of 2 kilowatts, take the whole thing for a spin, using two stage belt reductions and a magnetic encoder to keep track of the location at all times, allowing each unit to keep the others in sync as if they were all on the same team.
The Arduino Ventuno Q board is at the heart of the electronics, with an STM32 microcontroller monitoring a three-axis joystick and communicating with the motor controllers via a CAN bus, while the onboard Qualcomm Linux computer runs ROS 2 and the Nav2 navigation stack. To give the software a better bird’s-eye view, two RPLIDAR S3 sensors are mounted at opposite corners of the frame, allowing it to build a live map, detect obstacles, and plan the best route around them all in real-time.
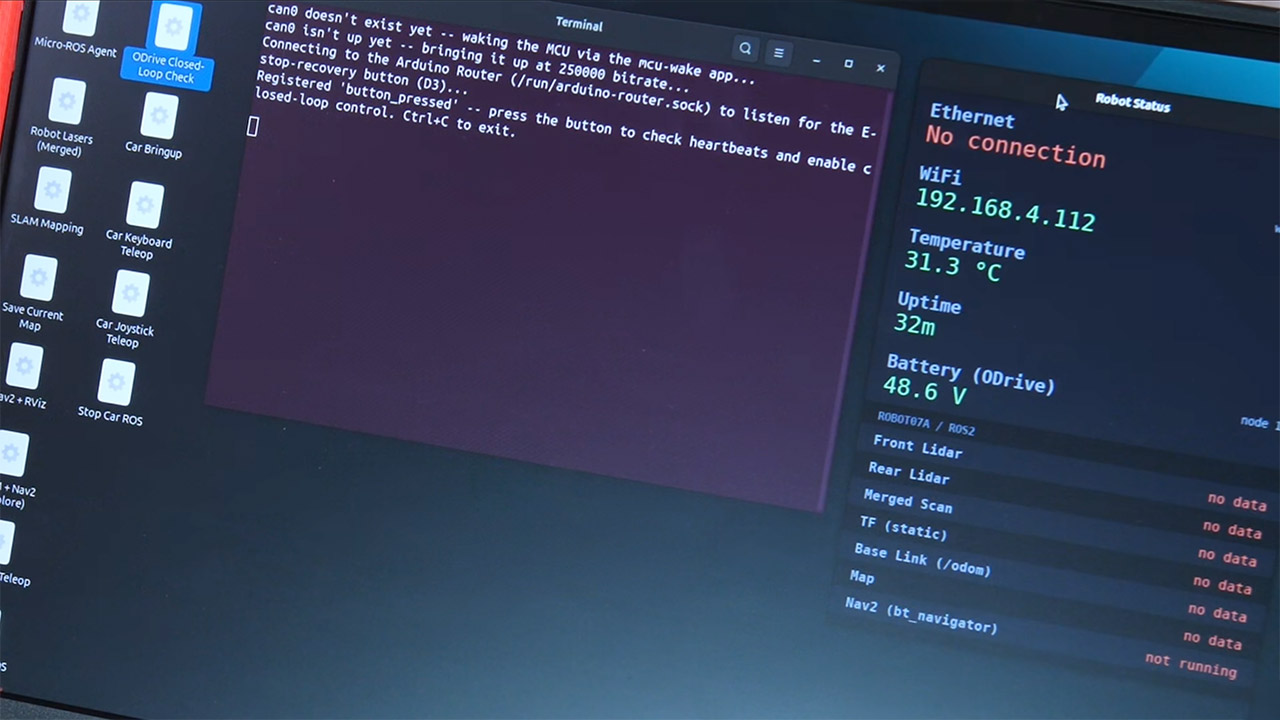
All of this is powered by four six-cell lithium polymer packs churning out 50 volts to the motors and only gets the job done because of a heavy duty contactor and an emergency stop button, and in all of the indoor tests they’ve run, the platform has been known to reach a pretty decent half a meter per second while chugging along behind a pre-set path of cones under full autonomous control or flinging it around on a dime with just a joystick.
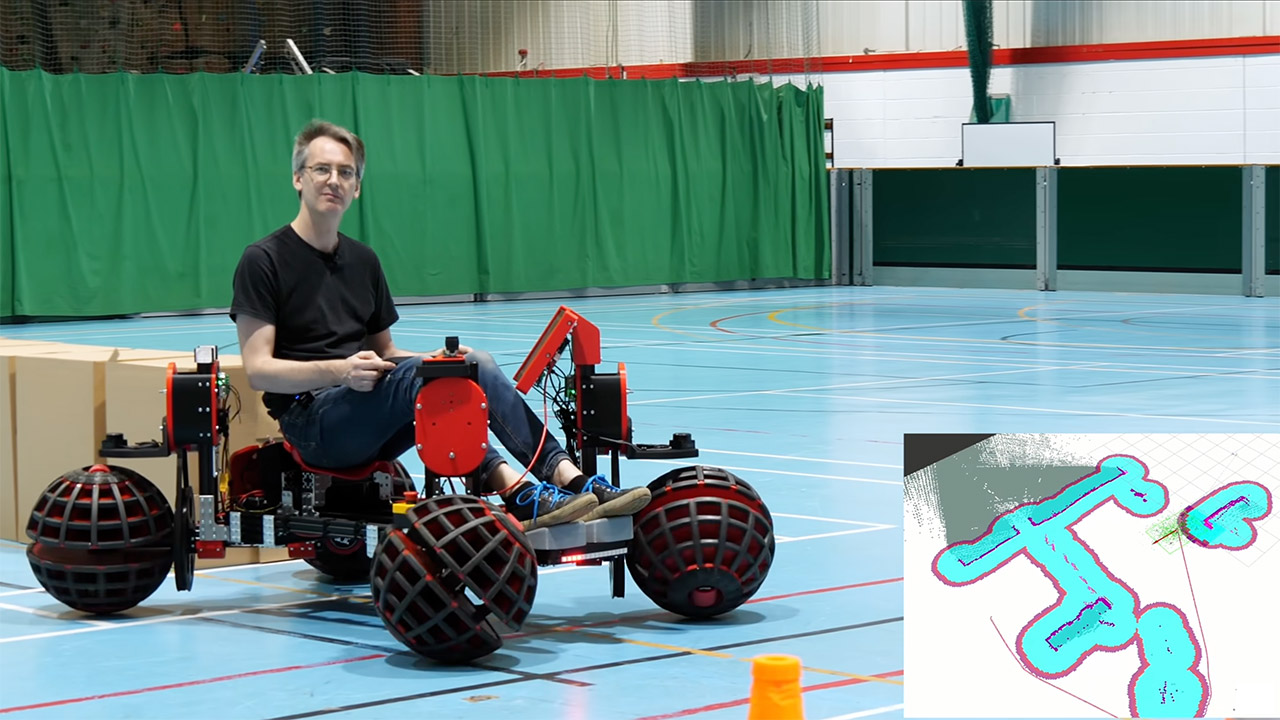
This combination of custom mechanical parts and cutting-edge software allows them to treat their direction as if it happens automatically on its own, while the wheels handle everything else, opening up a plethora of plain sailing possibilities for tight indoor maneuvering that no ordinary wheels could hope to match.
[Source]
James Bruton Builds Autonomous Ball Wheeled Omni Directional Car That Travels in Any Direction
#James #Bruton #Builds #Autonomous #Ball #Wheeled #Omni #Directional #Car #Travels #Direction